How Industrial Robots Adapt When Parts Arrive Out of Position
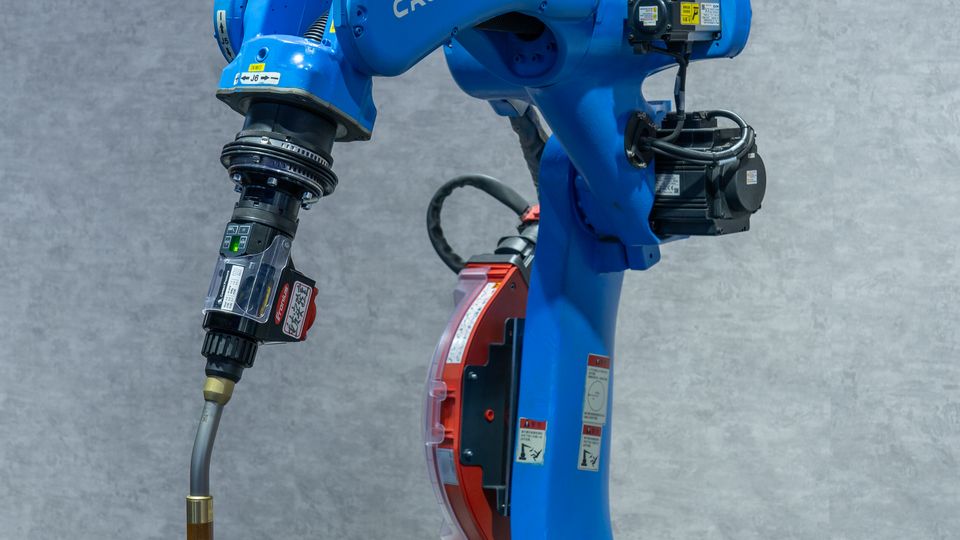
How Industrial Robots Adapt When Parts Arrive Out of Position
Cameras and controlled motion give a work cell room to accommodate variation in the parts it handles.
A fixed robot program assumes each part starts in the same place. A camera can estimate its pose, and the controller can adjust the pick or weld path before moving.
Lighting, shadows and reflective surfaces can change the camera's answer. Calibration should be checked after maintenance and whenever a camera, fixture or robot base moves.
A useful acceptance test includes awkward cases such as a flipped part, a partial obstruction and a missed detection. The system should report uncertainty and leave the station in a recoverable state.